

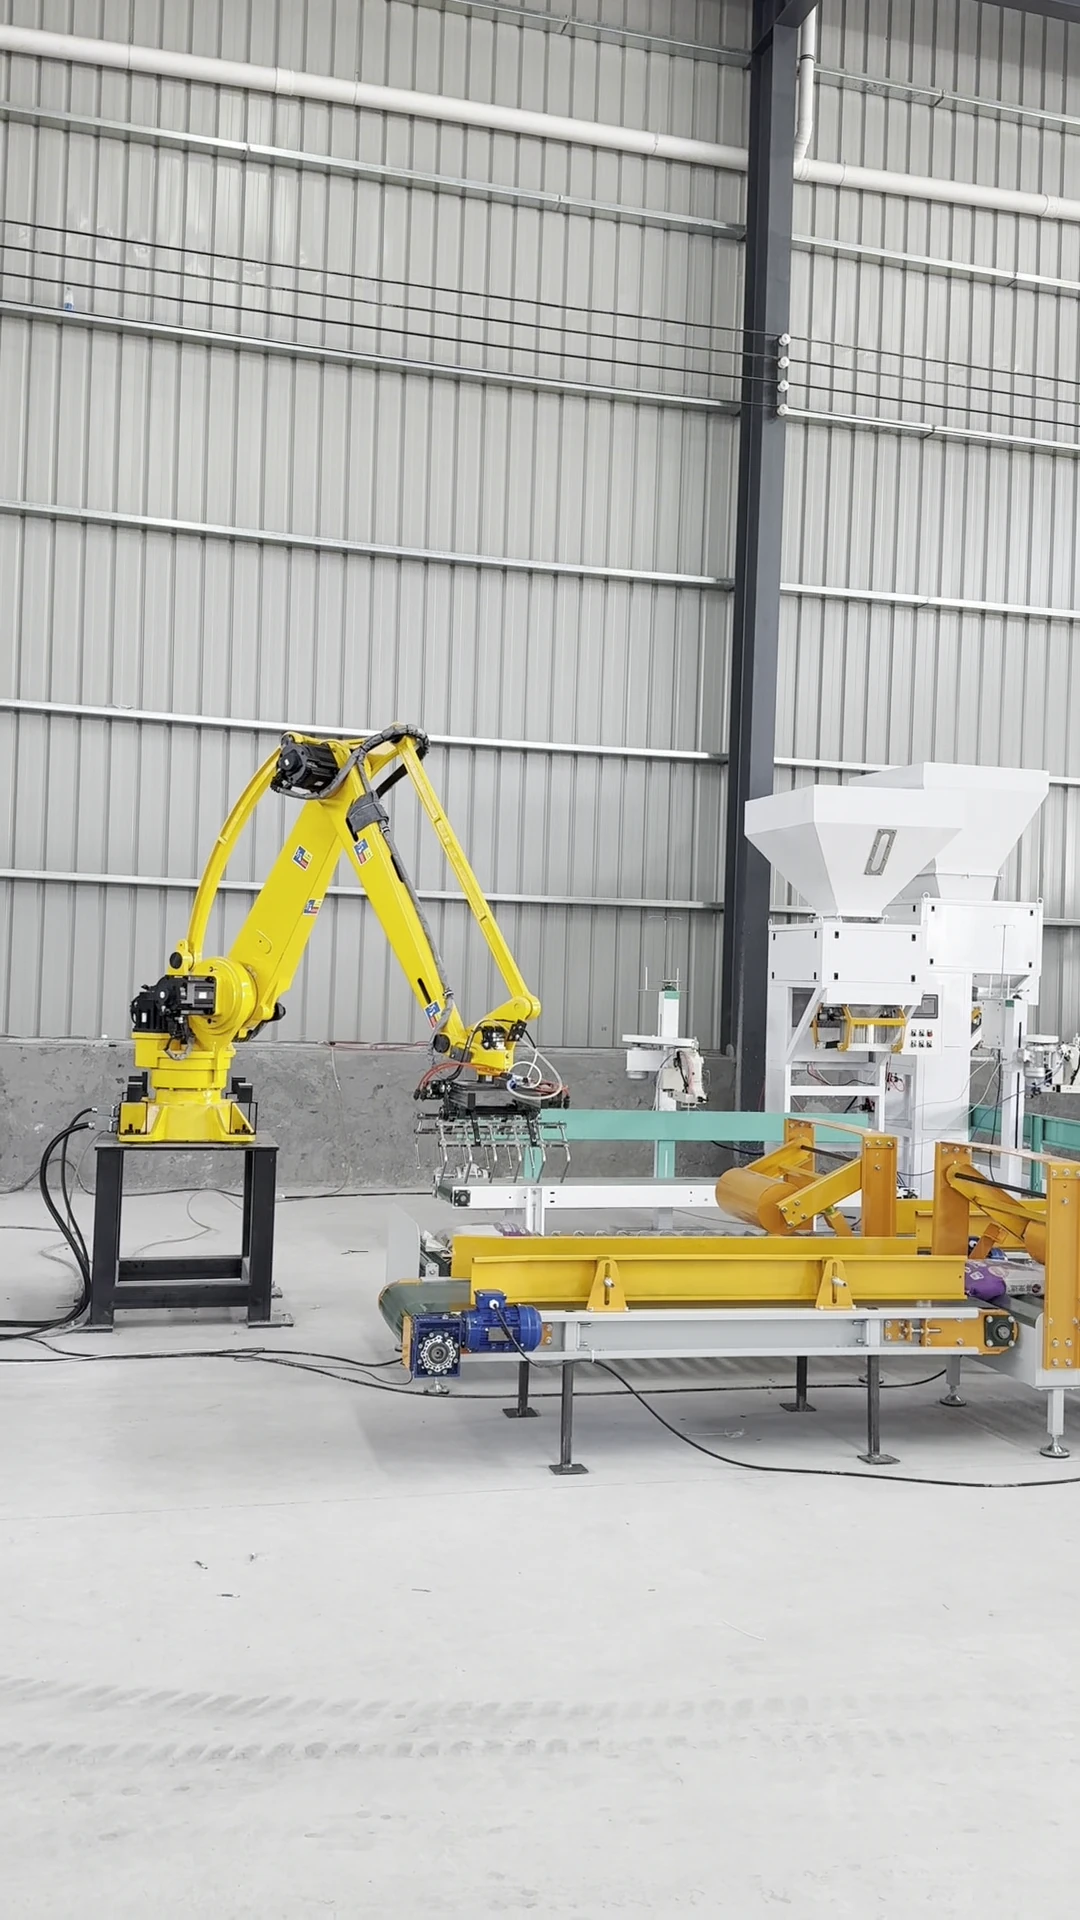
Robotic palletizing
A robot picks individual bags with a selected gripper and places them in the pallet pattern.
 WhatsApp
Stack filled bags in a planned pallet pattern. Match the method to bag condition, output and available space.
Review bag size, weight and condition.
Confirm the pallet and handling arrangement.
Match discharge, conveying and pick position.
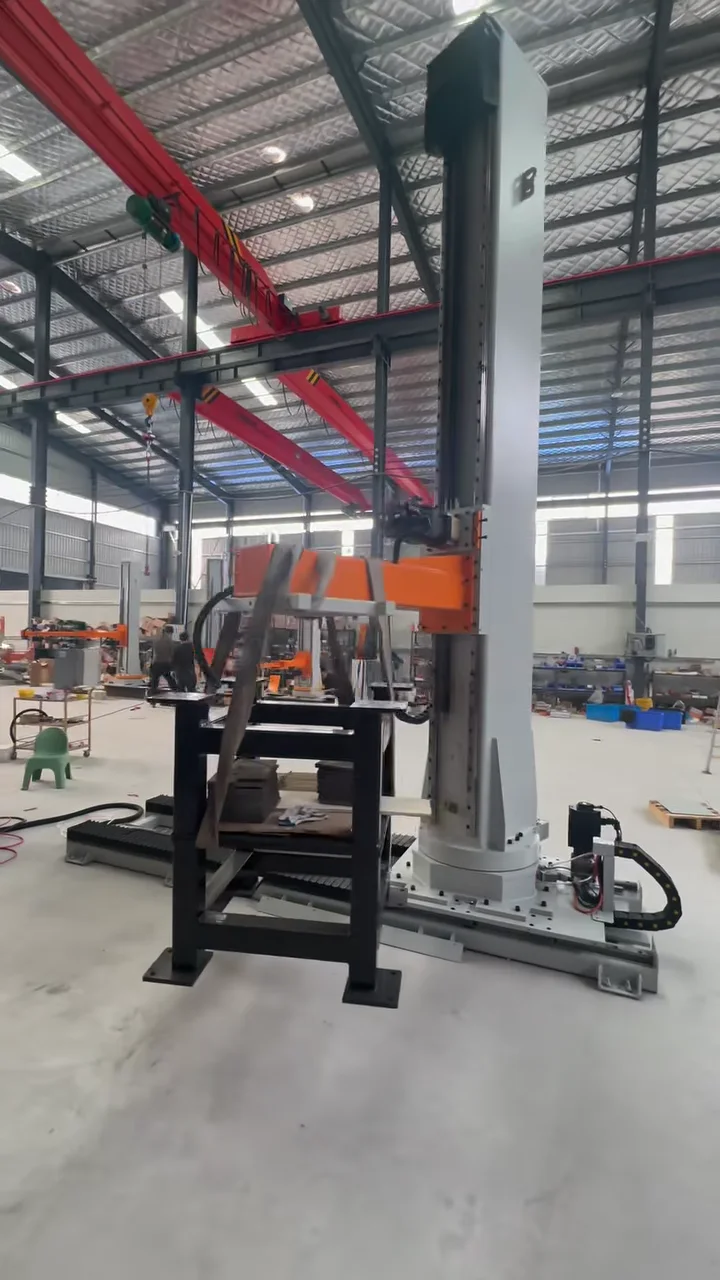
A selected gripper picks individual bags and places them in a pattern.
Bags are arranged into layers before stacking.
The column palletizer shown here is not a high-level layer system; confirm bag compatibility separately.
Prepare a consistent pick through conveying and bag conditioning. Confirm guarding, access and controls with the final workstation.
Planning resource: bag pallet patterns and pallet size.
A robot picks individual bags with a selected gripper and places them in the pallet pattern.
The workshop demonstration shows a column mechanism, not layer formation. Confirm bag handling compatibility for the application.
Wisdom integrates robotic workstations using purchased industrial robots. A column palletizer is a different mechanism, not a robot arm or high-level layer palletizer. The homepage column-machine visual shows carton handling; bag gripper compatibility must be reviewed separately.
Compare handling methods in the robotic versus high-level palletizing guide.
Bag transfer and stacking during workshop testing.
Conveying and bag conditioning prepare a consistent pick. New lines and existing packing machines need different interfaces.
Explore complete linesGuarding, access and controls are defined with the final workstation and site scope.
Send your material, operating requirements and site layout.